A robot that walks perfectly in simulation can break its own legs in under a second on the bench. Robot simulation vs reality is the gap between what a virtual model predicts and what the real sensors, actuators, mechanics, timing and control software do. Close it by checking coordinate frames, dynamics, latency, limits and safety controls one step at a time on real hardware. Don't assume simulated success carries over.
One wrong assumption can turn a promising controller into an instant mechanical failure. Careful testing keeps the failures small and easier to diagnose.
Why did an inverted IMU axis cause the robot to break?
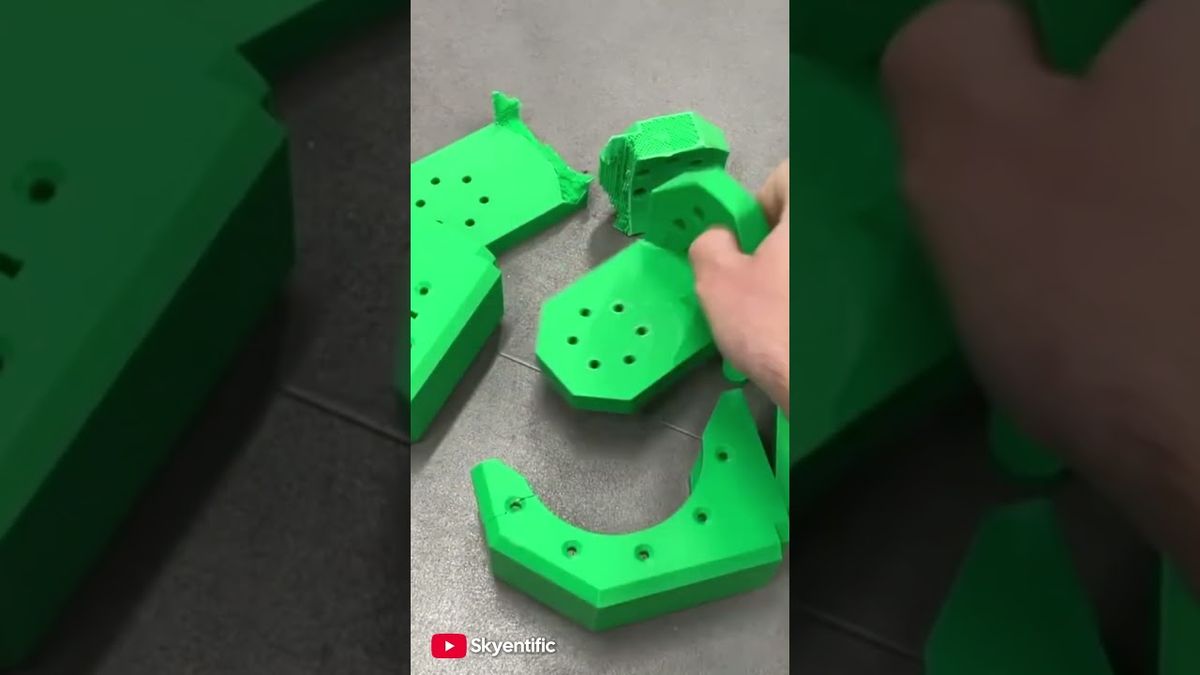
The IMU data was inverted on the Z-axis, so the controller believed the robot was upside down. It answered with extremely fast motions. Both legs broke in less than half a second.
What's an IMU doing in all this? An inertial measurement unit works out orientation and motion from accelerometers and gyroscopes. Get a sign wrong, mount it with the wrong transform, or mix up coordinate conventions, and the controller's idea of gravity and pose flips. If the control loop trusts that bad state, it may throw aggressive commands at a problem that doesn't exist.
Nobody could stop it by hand. It was over too fast, and what remained was a pair of broken legs and a nagging question about whether a wire had been damaged too.
We'd put it bluntly: sensor transformations are safety-critical configuration. Call them minor data cleanup and sooner or later a robot gets hurt.
Why can basic robot walking take months to achieve?
Walking looks simple because you only see the result. Underneath sits a pile of engineering, and progress rarely runs in a straight line.
On this project, a transfer expected to take one or two weeks became seven months of active work, and nearly a year of development overall, before the robot could move forward and backward.
Where did the time go? Mostly not into tuning a walking policy. It went into hunting for differences between simulation and hardware, diagnosing sensing errors, repairing mechanical damage, checking for possible wiring damage, and rerunning tests after every fix. A task that looks physically simple can demand sustained work across mechanical engineering, embedded systems, simulation, controls, data capture and operations.
Not every robot will take this long. The planning lesson is narrower, and more useful: put validation, instrumentation, repair, regression testing and iteration in the schedule. A working simulation is a milestone, and plenty of development still comes after it.
Robot simulation vs reality: why does simulated behavior differ?
Because a simulation is only an approximation of the robot and its world. The real machine finds every modeling error and every implementation detail you missed, so a controller that looks stable in robotics simulation can still fail the moment you transfer it unchecked.
Treat a walking robot as a compound AI system: several parts interact, and any of them can be off.
- The simulator's mass, center of gravity, friction, backlash and structural compliance may not match the hardware.
- Real sensors add noise, bias, calibration errors and communication delays.
- Actuators come with torque limits, temperature limits, response delays and behavior that shifts under load.
- Axis directions, units and sign conventions can differ between simulator, firmware and control software.
In simulation, a failure means pressing reset. On a physical robot, the same bad command can snap a leg, damage a cable or create a safety hazard.
Varying mass, friction, latency and sensor noise makes a simulator more representative. You still have to test on hardware.

How should teams test a walking robot safely?
Slowly, in stages, moving from software checks to constrained hardware trials. Before the robot is allowed to move more on its own, each stage should cap the energy, duration and physical range of a possible failure.
In order:
- Verify sensor conventions. With the robot stationary and then moved by hand, confirm axis direction, units, sign, mounting orientation, timestamps and expected readings.
- Test components alone. Run single joints and sensors at low speed before starting a whole-body controller.
- Constrain early trials with conservative torque, velocity, position and duration limits, plus suitable physical restraints where appropriate.
- Review the evidence between tests: logs, state estimates, commands, alerts, and the hardware itself. Widen the operating envelope after that.
You'll also want AI observability across model outputs, controller state, sensor streams and infrastructure.
Emergency stops matter. Still, a failure that unfolds in a fraction of a second can beat any human reaction, so prevention has to come earlier: validated inputs, bounded commands, automatic limits.

How Hyperlake helps
Hyperlake is the AI cloud for your team and your agents, on your cloud. It can provide a repeatable Physical AI development environment, with simulation orchestration, training, data and model services running in an organization's or client's infrastructure. It can integrate tools such as NVIDIA OSMO, Omniverse, Isaac Sim and Isaac Lab, subject to licensing and validated integration, while shared controls support observability, lifecycle management, access and audit. To discuss the environment and policies a robotics workload needs, talk to our team.
Frequently asked questions
Can a robot that walks in simulation be expected to walk in reality?
Not without validation. Simulation only shows that the controller works under the model's assumptions; it says nothing about whether those assumptions match the physical robot. Real hardware brings sensor errors, timing differences, actuator limits, structural compliance, friction changes and manufacturing tolerances. Validate the controller step by step under constrained conditions.
How should IMU axis conventions be validated before deployment?
Write down the simulator, sensor, body and world coordinate frames first. Then check each axis and sign against known physical orientations and slow manual movements. Look at units, timestamps, mounting transforms and gravity direction too, all before you enable autonomous motion. The recorded sensor values should match independently known robot poses.
Does sim-to-real training eliminate the need for hardware tests?
No. Techniques like parameter variation expose a controller to differences in mass, friction, latency and sensor noise, so it copes better with expected variation. They can't represent every wiring error, mounting mistake, damaged component, timing issue or unmodeled physical interaction. Carefully bounded hardware testing stays essential.